Modern Defense Technology ›› 2026, Vol. 54 ›› Issue (1): 85-95.DOI: 10.3969/j.issn.1009-086x.2026.01.008
• PAPERS • Previous Articles Next Articles
Jiawen ZHUO1, Shouxia SHI1, Dengwei XIAO2, Chunwen LI1, Na FAN1
Received:
Revised:
Online:
Published:
卓佳文1, 史守峡1, 肖登伟2, 李春文1, 樊娜1
作者简介:
Abstract:
This study designed an optimal control algorithm based on linear quadratic regulator (LQR) and proposed the integration of output residual integral control to improve the performance of the optimal controller. A controllable and observable model of the servo system was built under friction-neglected conditions. Based on the LQR optimal control theory, the optimal control law for the system was derived. The influence of friction on the controller's performance was studied, and integral control was incorporated into the optimal control loop to improve steady-stage performance. Experimental results show that, compared with the PID lead-lag compensator, the proposed optimal controller exhibits zero overshoot during the presetting stage, reduces settling time by 47%, decreases steady-stage response delay by more than 55% while lowering the decoupling rate by over 50%. With the addition of output residual integral control, the issues of overshoot and tailing caused by friction in the steady stage are effectively eliminated, resulting in a decoupling rate below 4% and a further delay reduction exceeding 40%. Vibration tests indicate that the designed optimal controller possesses both stability and robustness, thereby laying a foundation for the future engineering application of the optimal control method in product models.
Key words: semi-strapdown seeker, servo mirror, optimal control, linear quadratic regulator, friction
摘要:
设计了基于线性二次型的最优控制算法,提出利用输出残差积分控制提升最优控制器性能。在忽略摩擦的条件下,建立伺服系统的可控、可观测模型,根据线性二次型最优控制理论,求解伺服系统的最优控制律;研究摩擦对控制器性能造成的影响,并在最优控制回路中加入残差积分控制,提升了稳定阶段系统性能。试验结果表明,对比PID超前-滞后校正控制器,该控制器预置阶段无超调量、调节时间缩短了47%,稳定阶段响应延时减小55%以上,去耦率减小50%以上。加入残差积分控制后,解决了稳定阶段摩擦带来的曲线畸变(平顶与拖尾)问题,去耦率小于4%,延时减小40%以上。振动试验结果表明,设计的最优控制器具有稳定性和鲁棒性,为后续最优控制方法在型号产品上的工程化应用奠定了基础。
关键词: 半捷联导引头, 伺服镜, 最优控制, 线性二次型, 摩擦
CLC Number:
TP273
Jiawen ZHUO, Shouxia SHI, Dengwei XIAO, Chunwen LI, Na FAN. Performance Improvement of Seeker Optimal Control System with Semi-strapdown Servo Mirror[J]. Modern Defense Technology, 2026, 54(1): 85-95.
卓佳文, 史守峡, 肖登伟, 李春文, 樊娜. 再论导引头半捷联伺服镜最优控制系统的性能提升[J]. 现代防御技术, 2026, 54(1): 85-95.
/ Recommend
Add to citation manager EndNote|Ris|BibTeX
URL: https://www.xdfyjs.cn/EN/10.3969/j.issn.1009-086x.2026.01.008
https://www.xdfyjs.cn/EN/Y2026/V54/I1/85
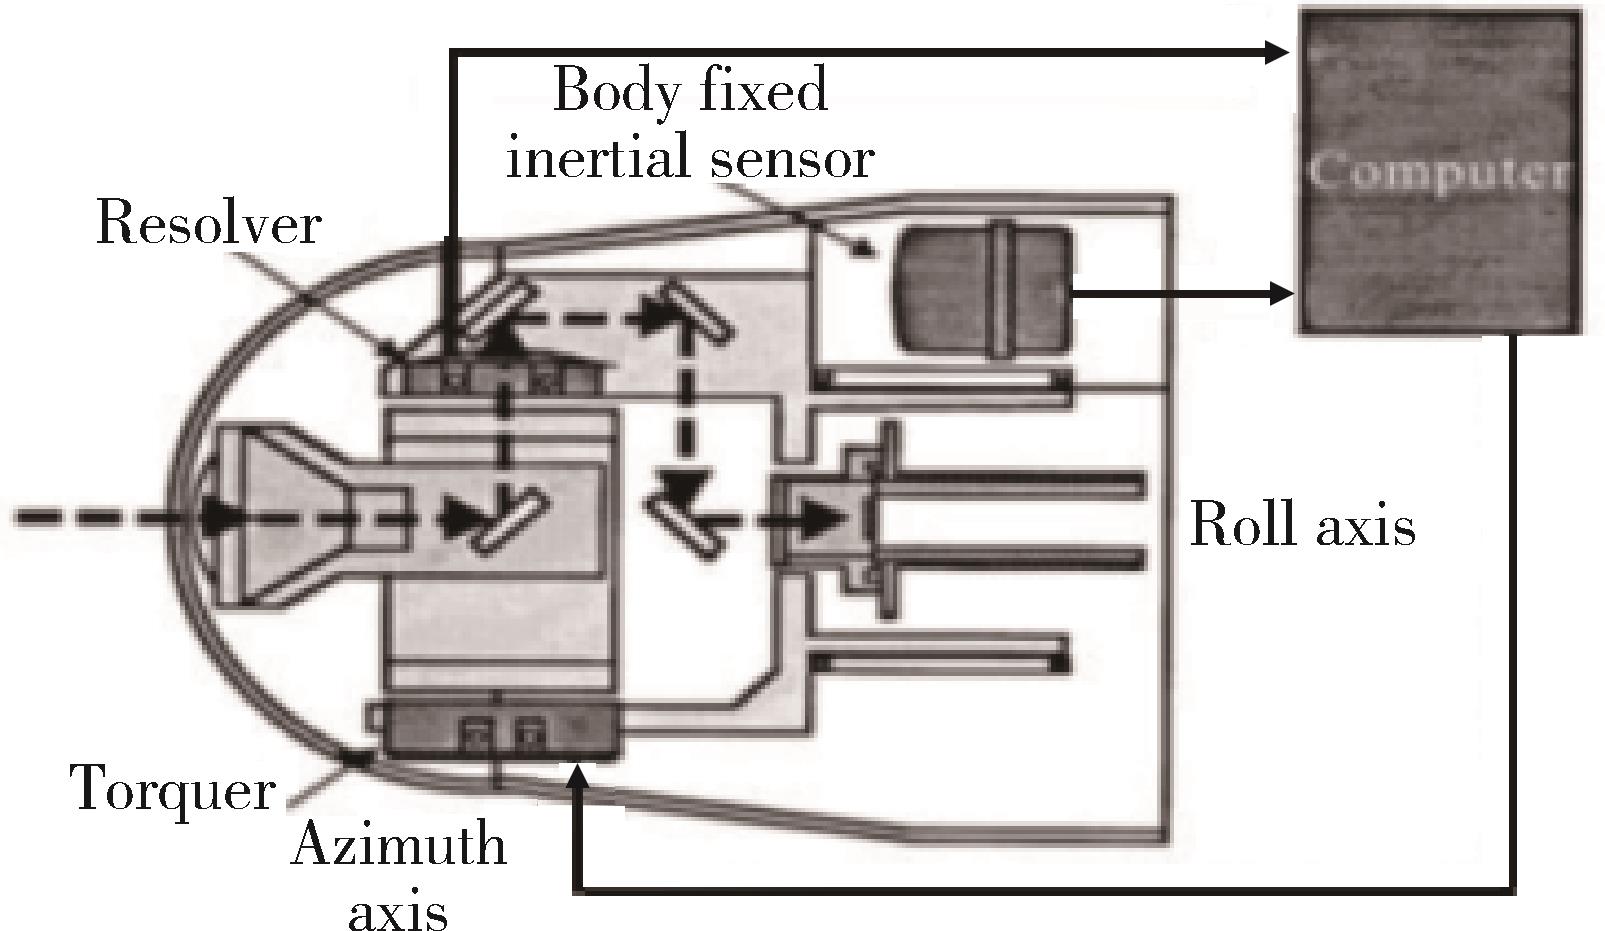
Fig. 1 Semi-strapdown servo system
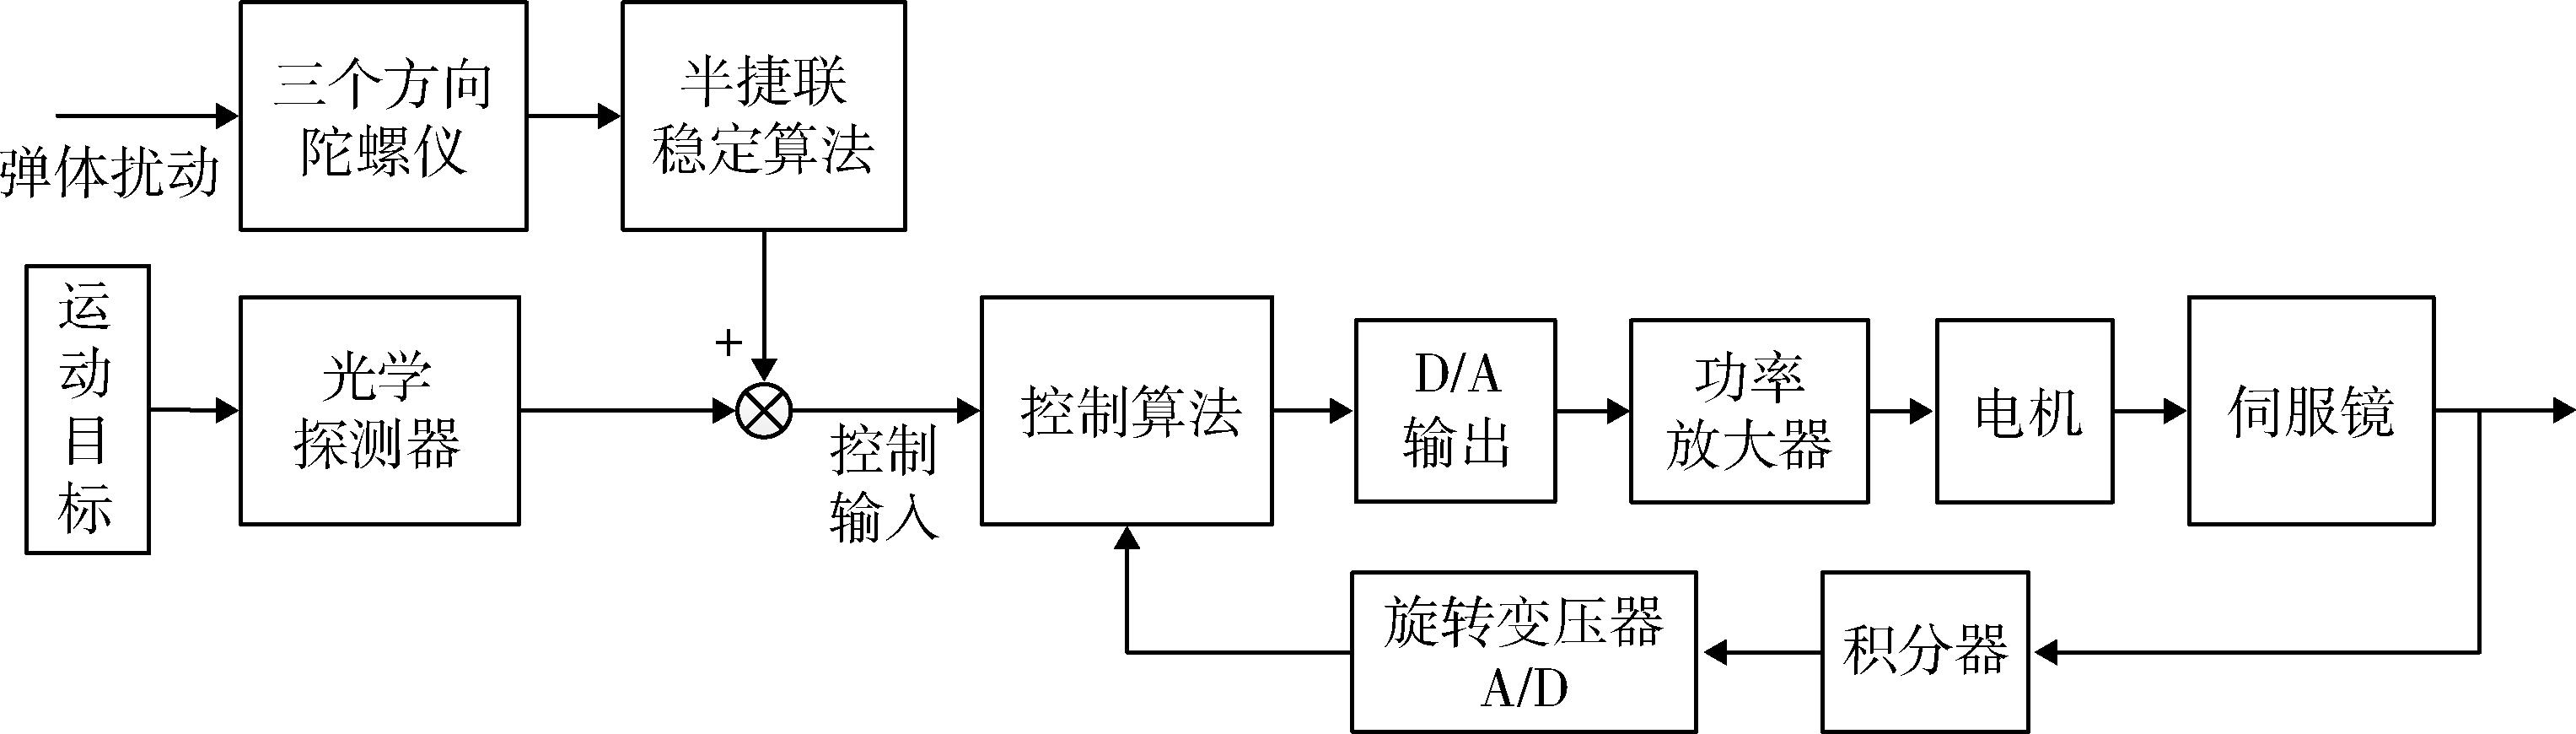
Fig.2 Semi-strapdown stability block of servo mirror
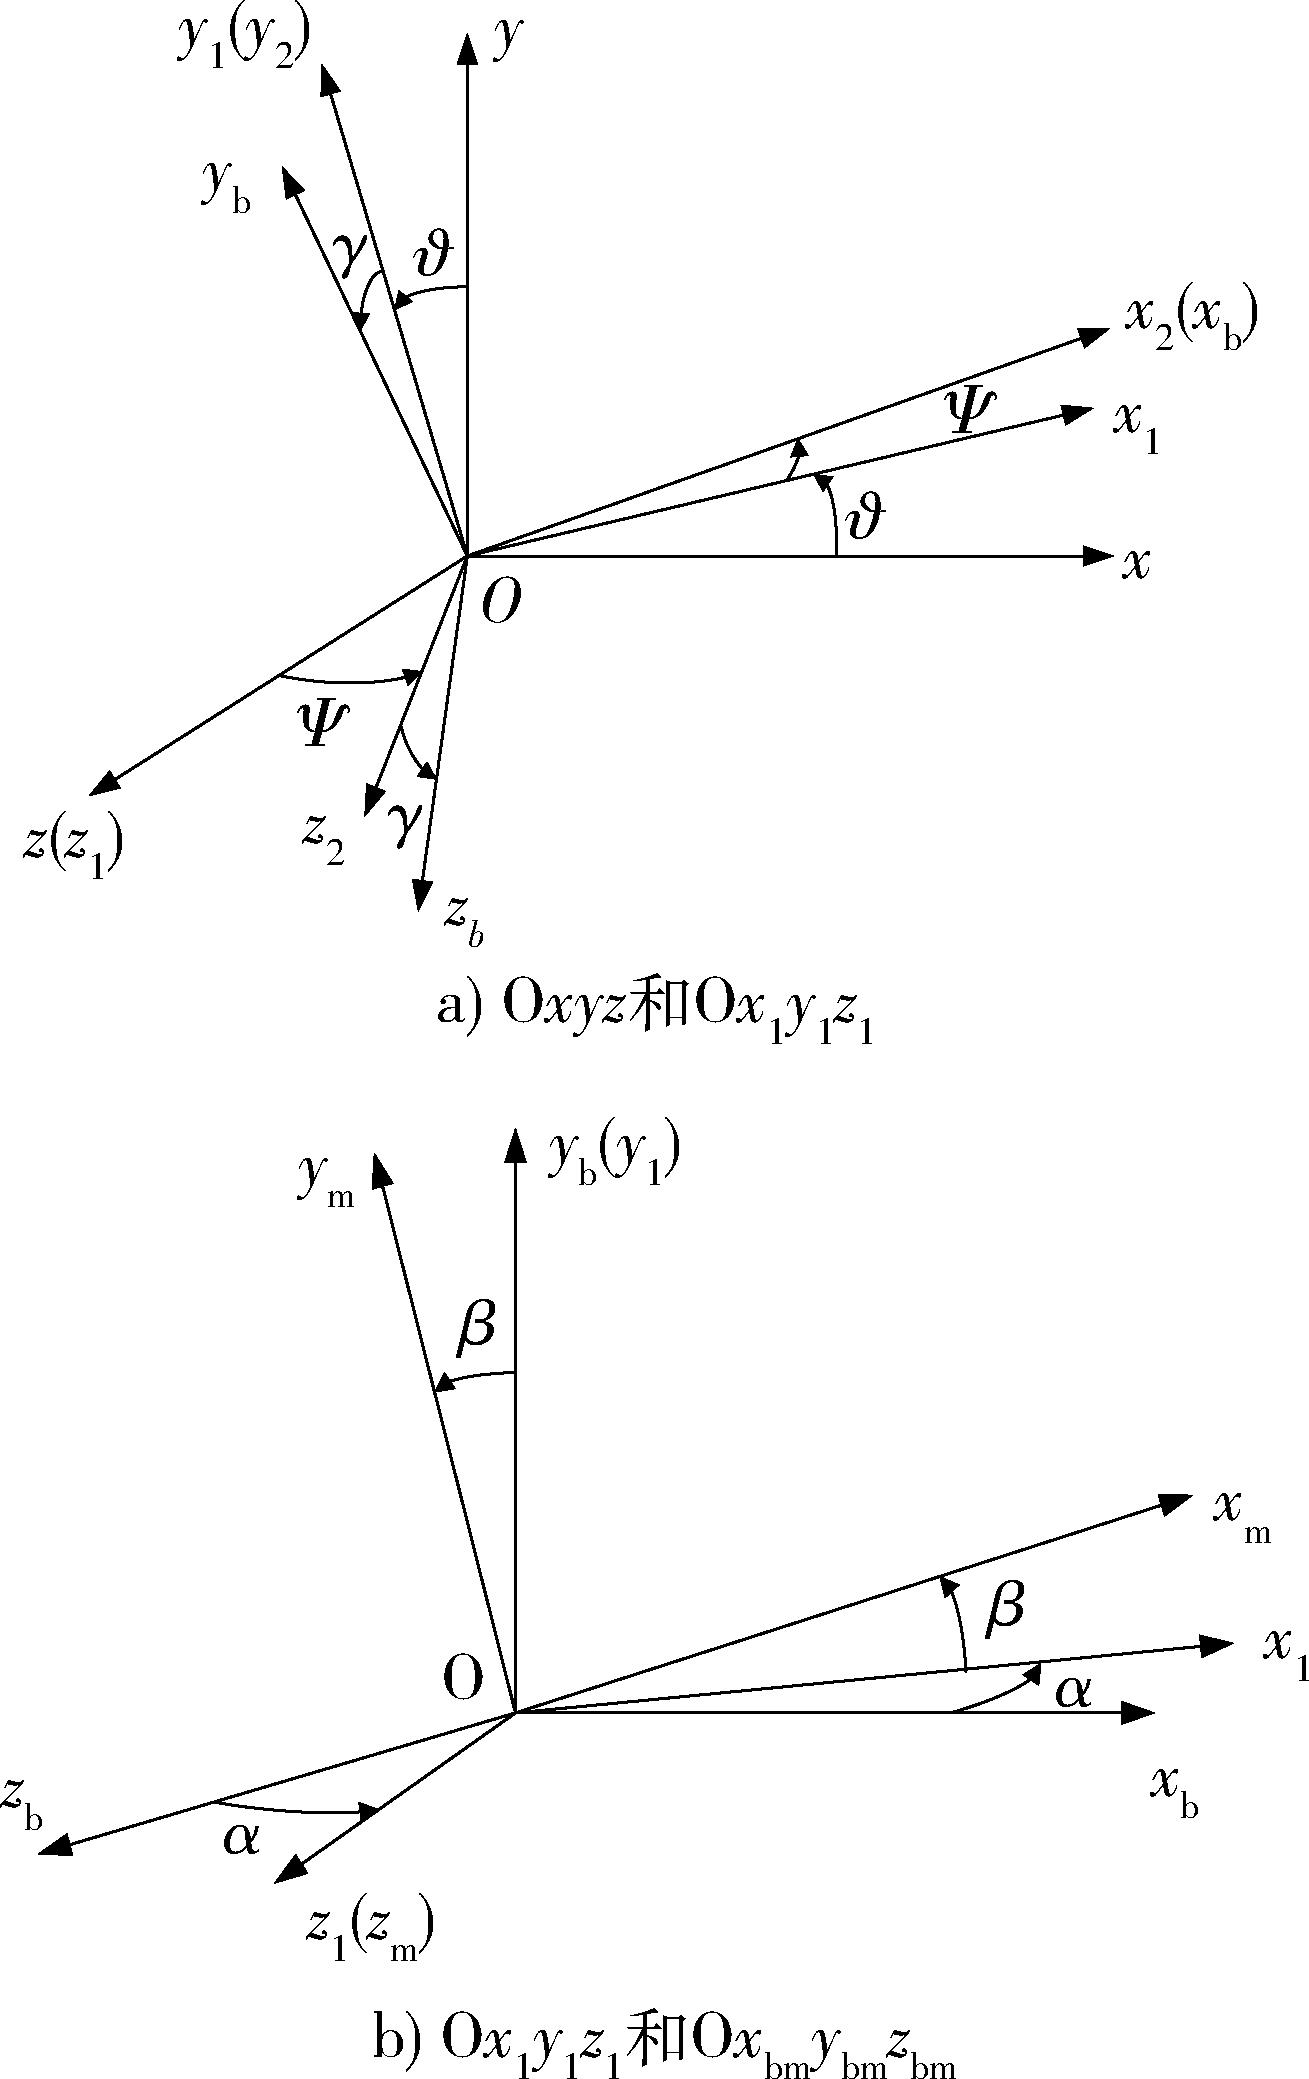
Fig. 3 Coordinate system
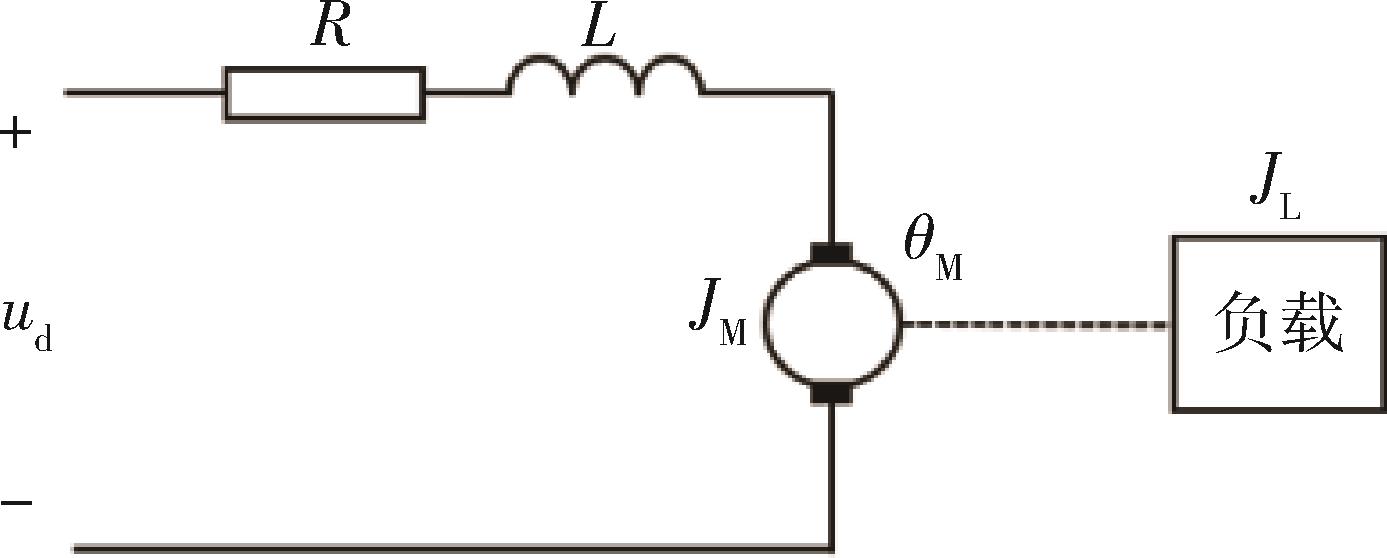
Fig. 4 Dc torque motor schematic diagram
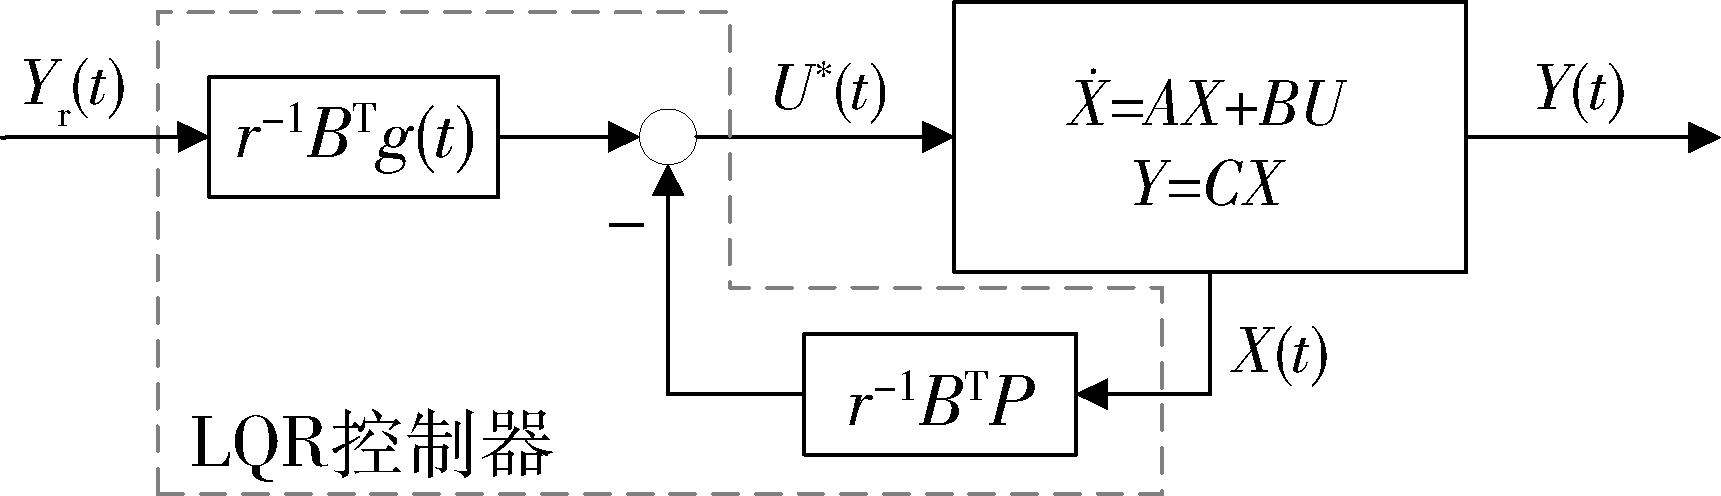
Fig. 5 Optimal control for LQR tracker problem
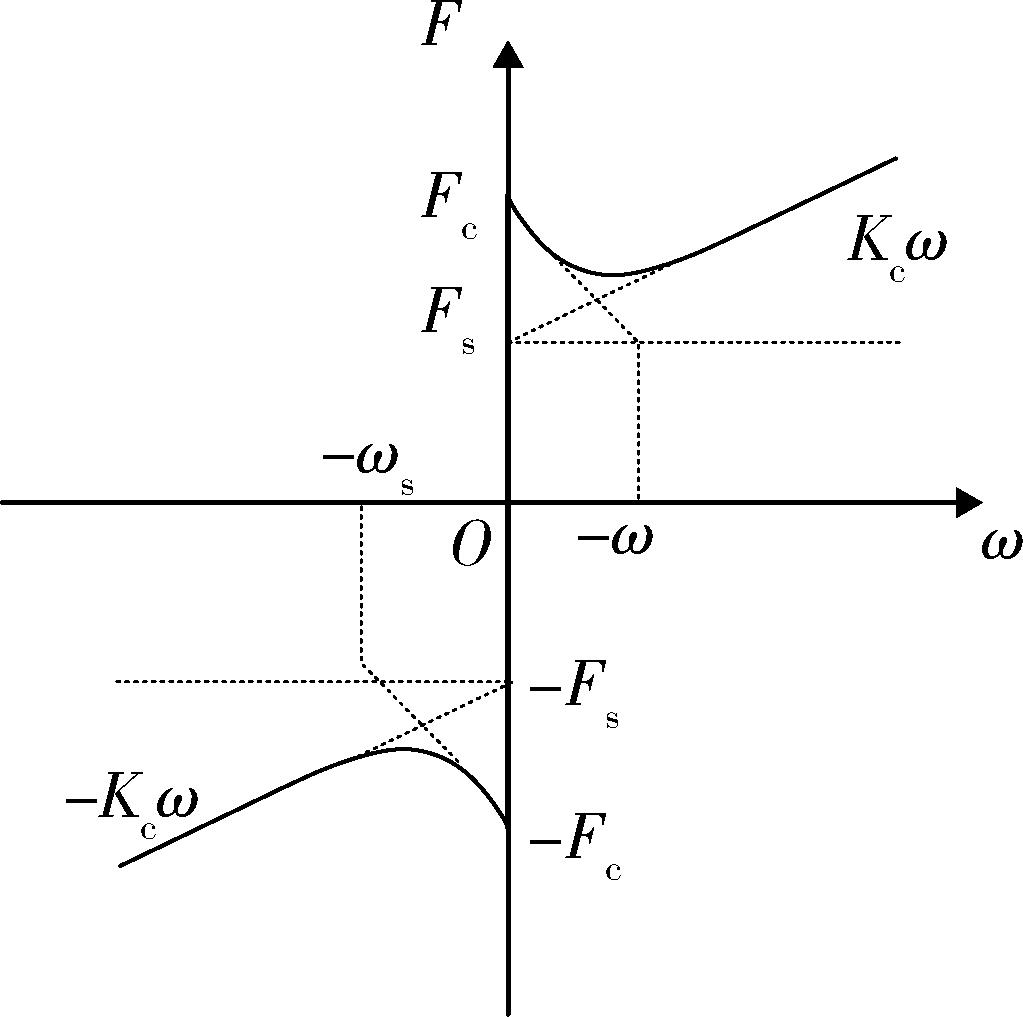
Fig. 6 Stribeck friction model
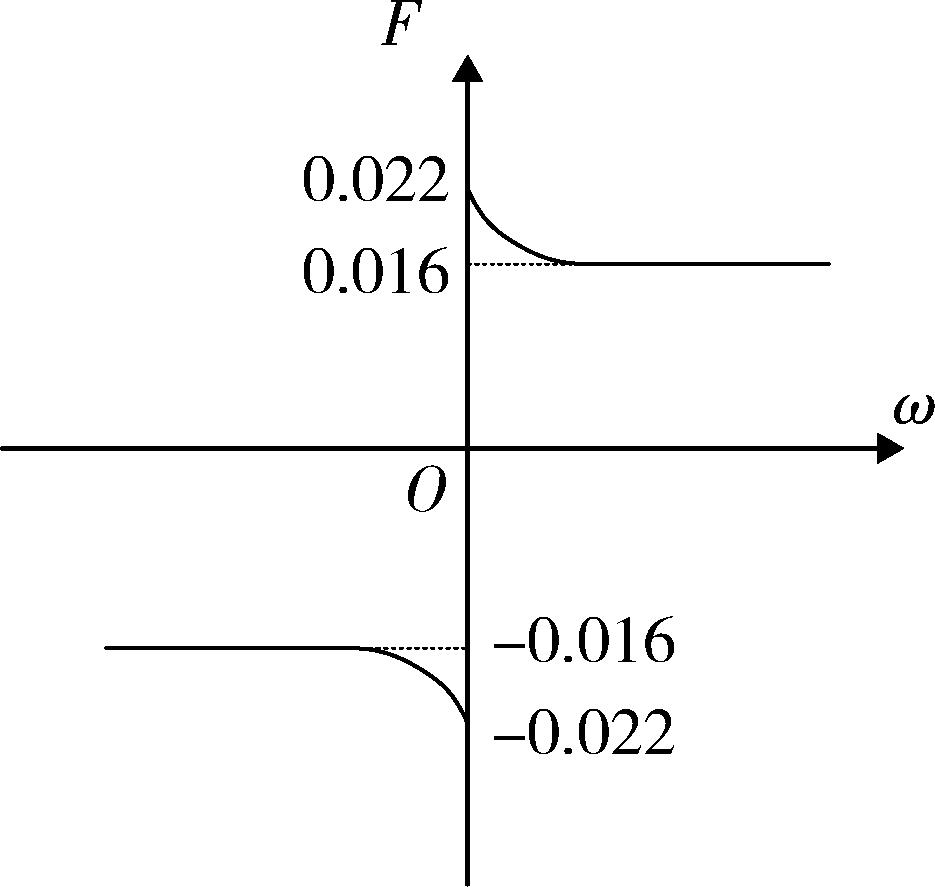
Fig. 7 Friction torque model of system
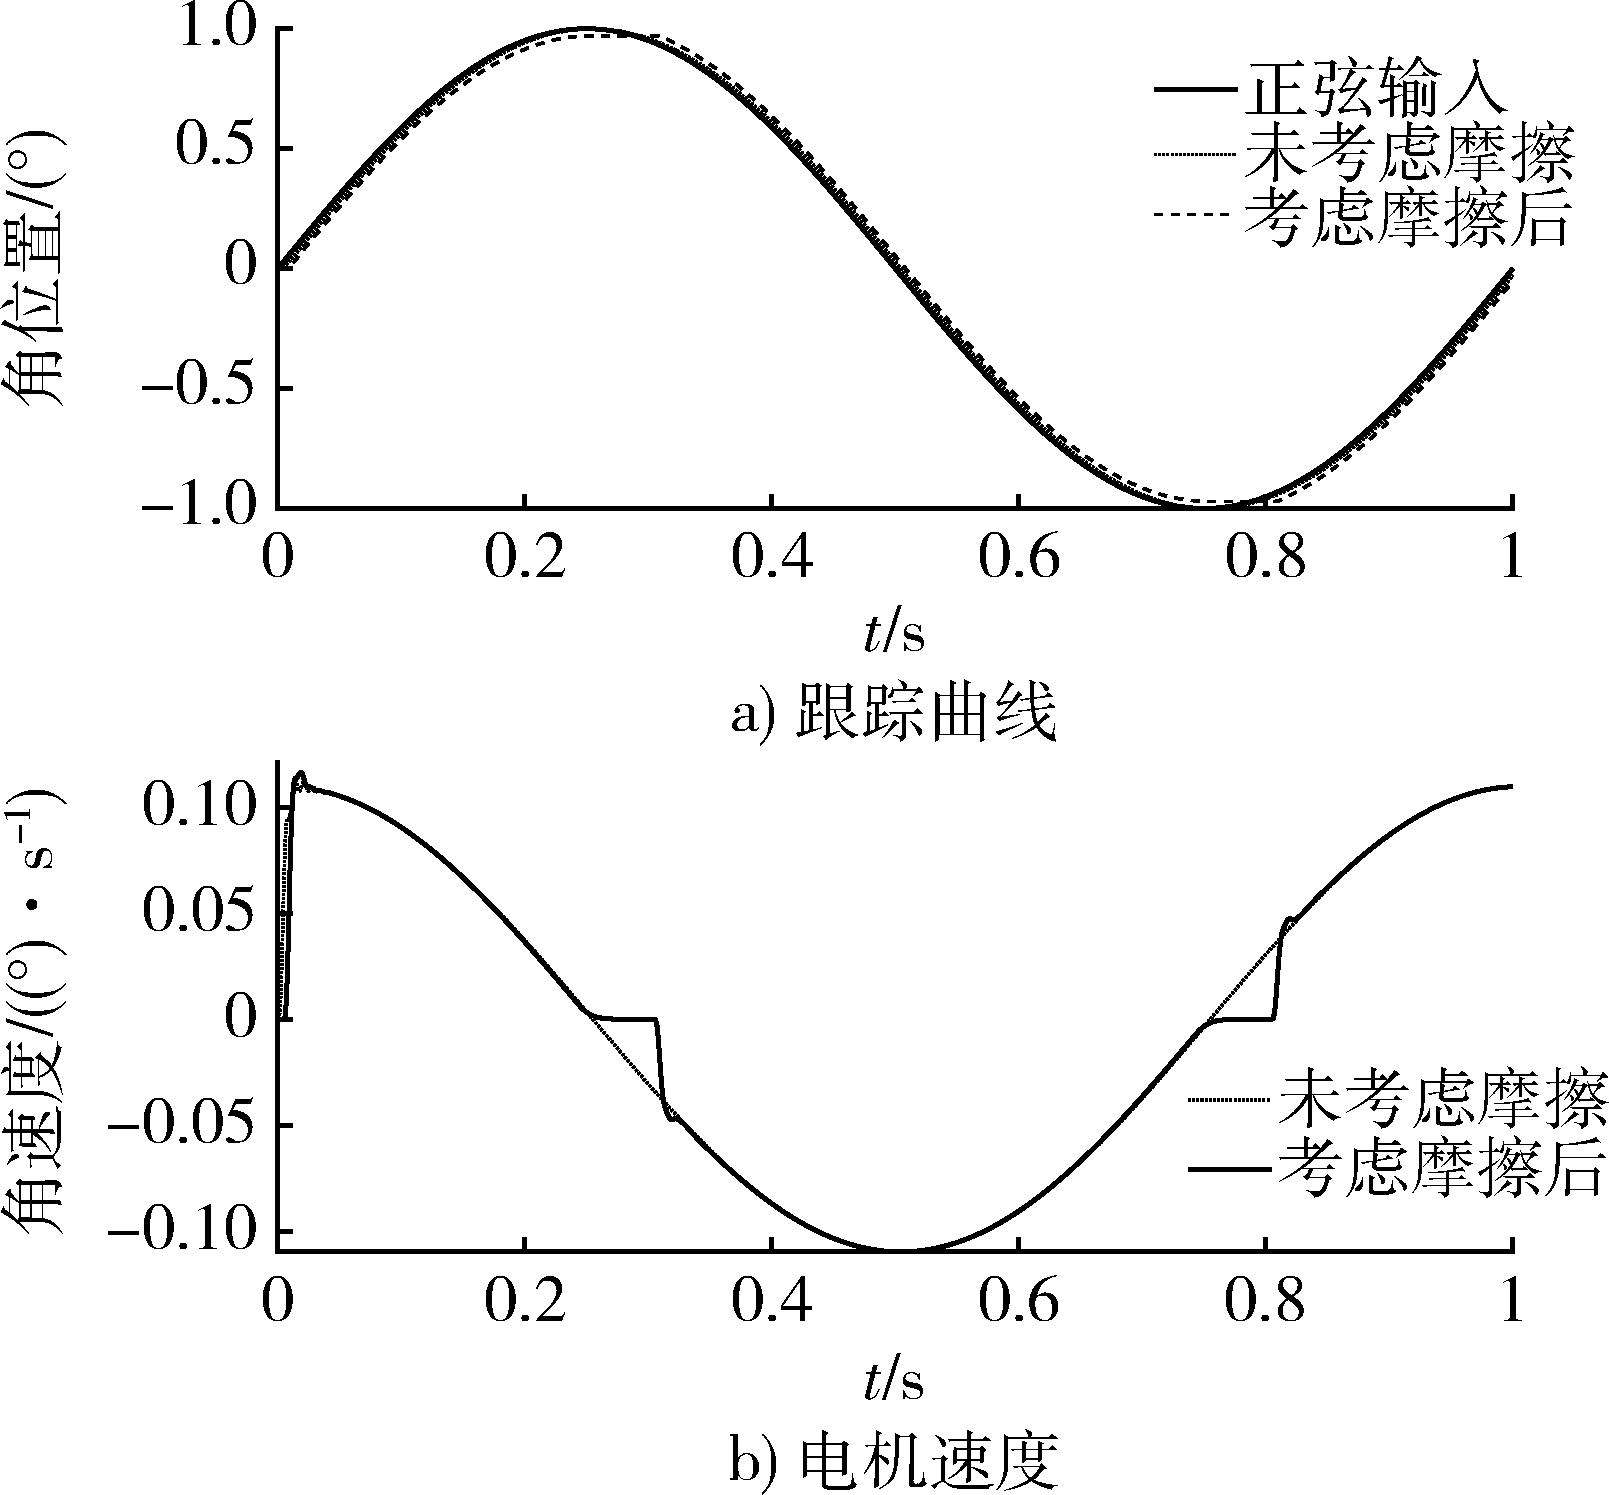
Fig. 8 Simulation results with friction
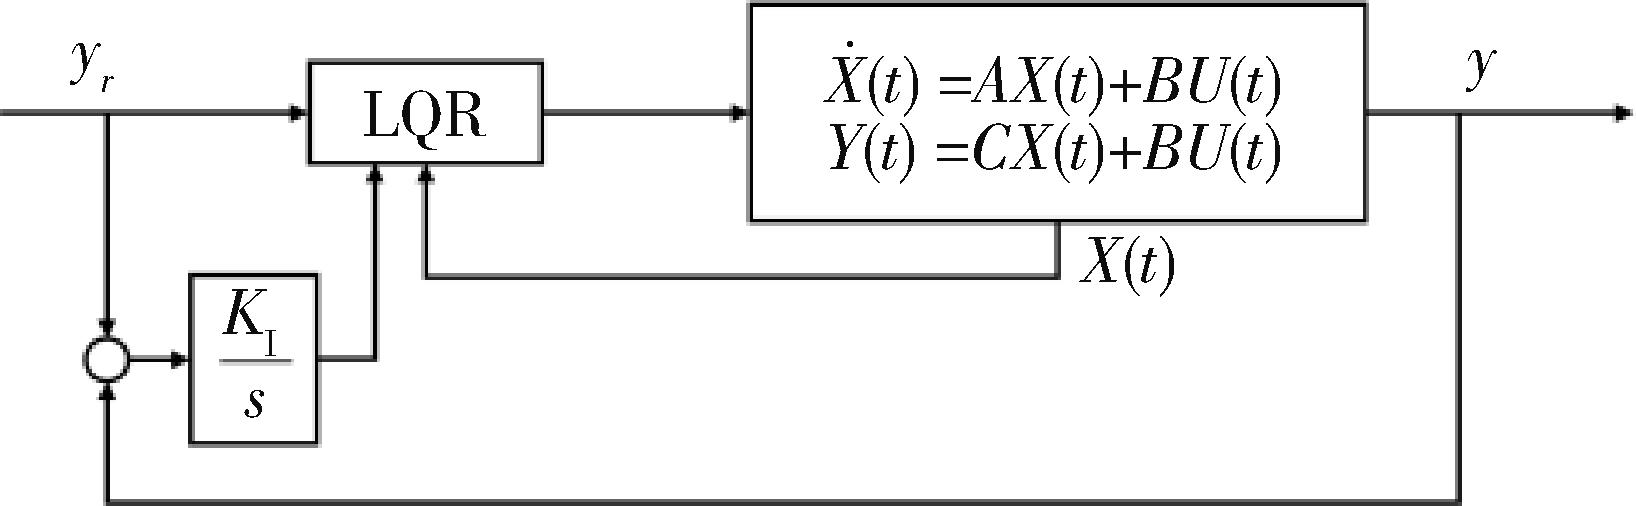
Fig. 9 Block diagram of integral control
Table 1 Parameters of servo system inner frame model
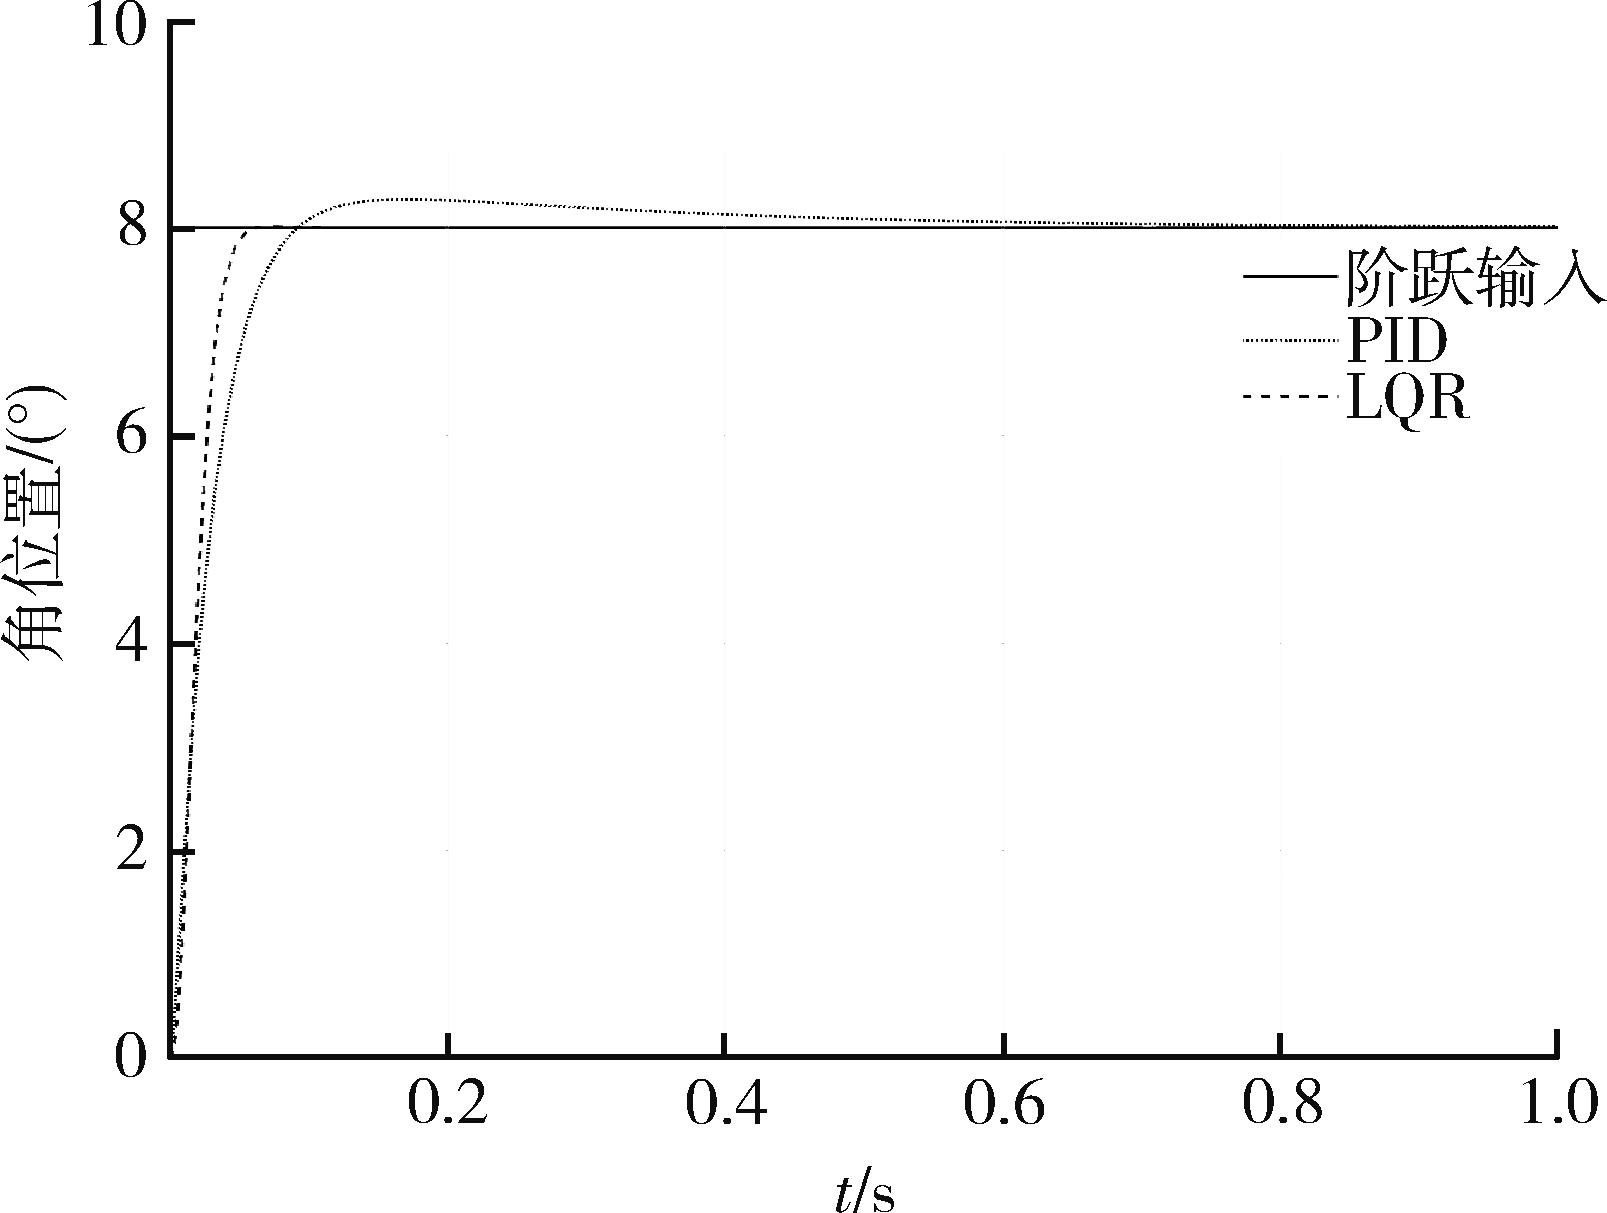
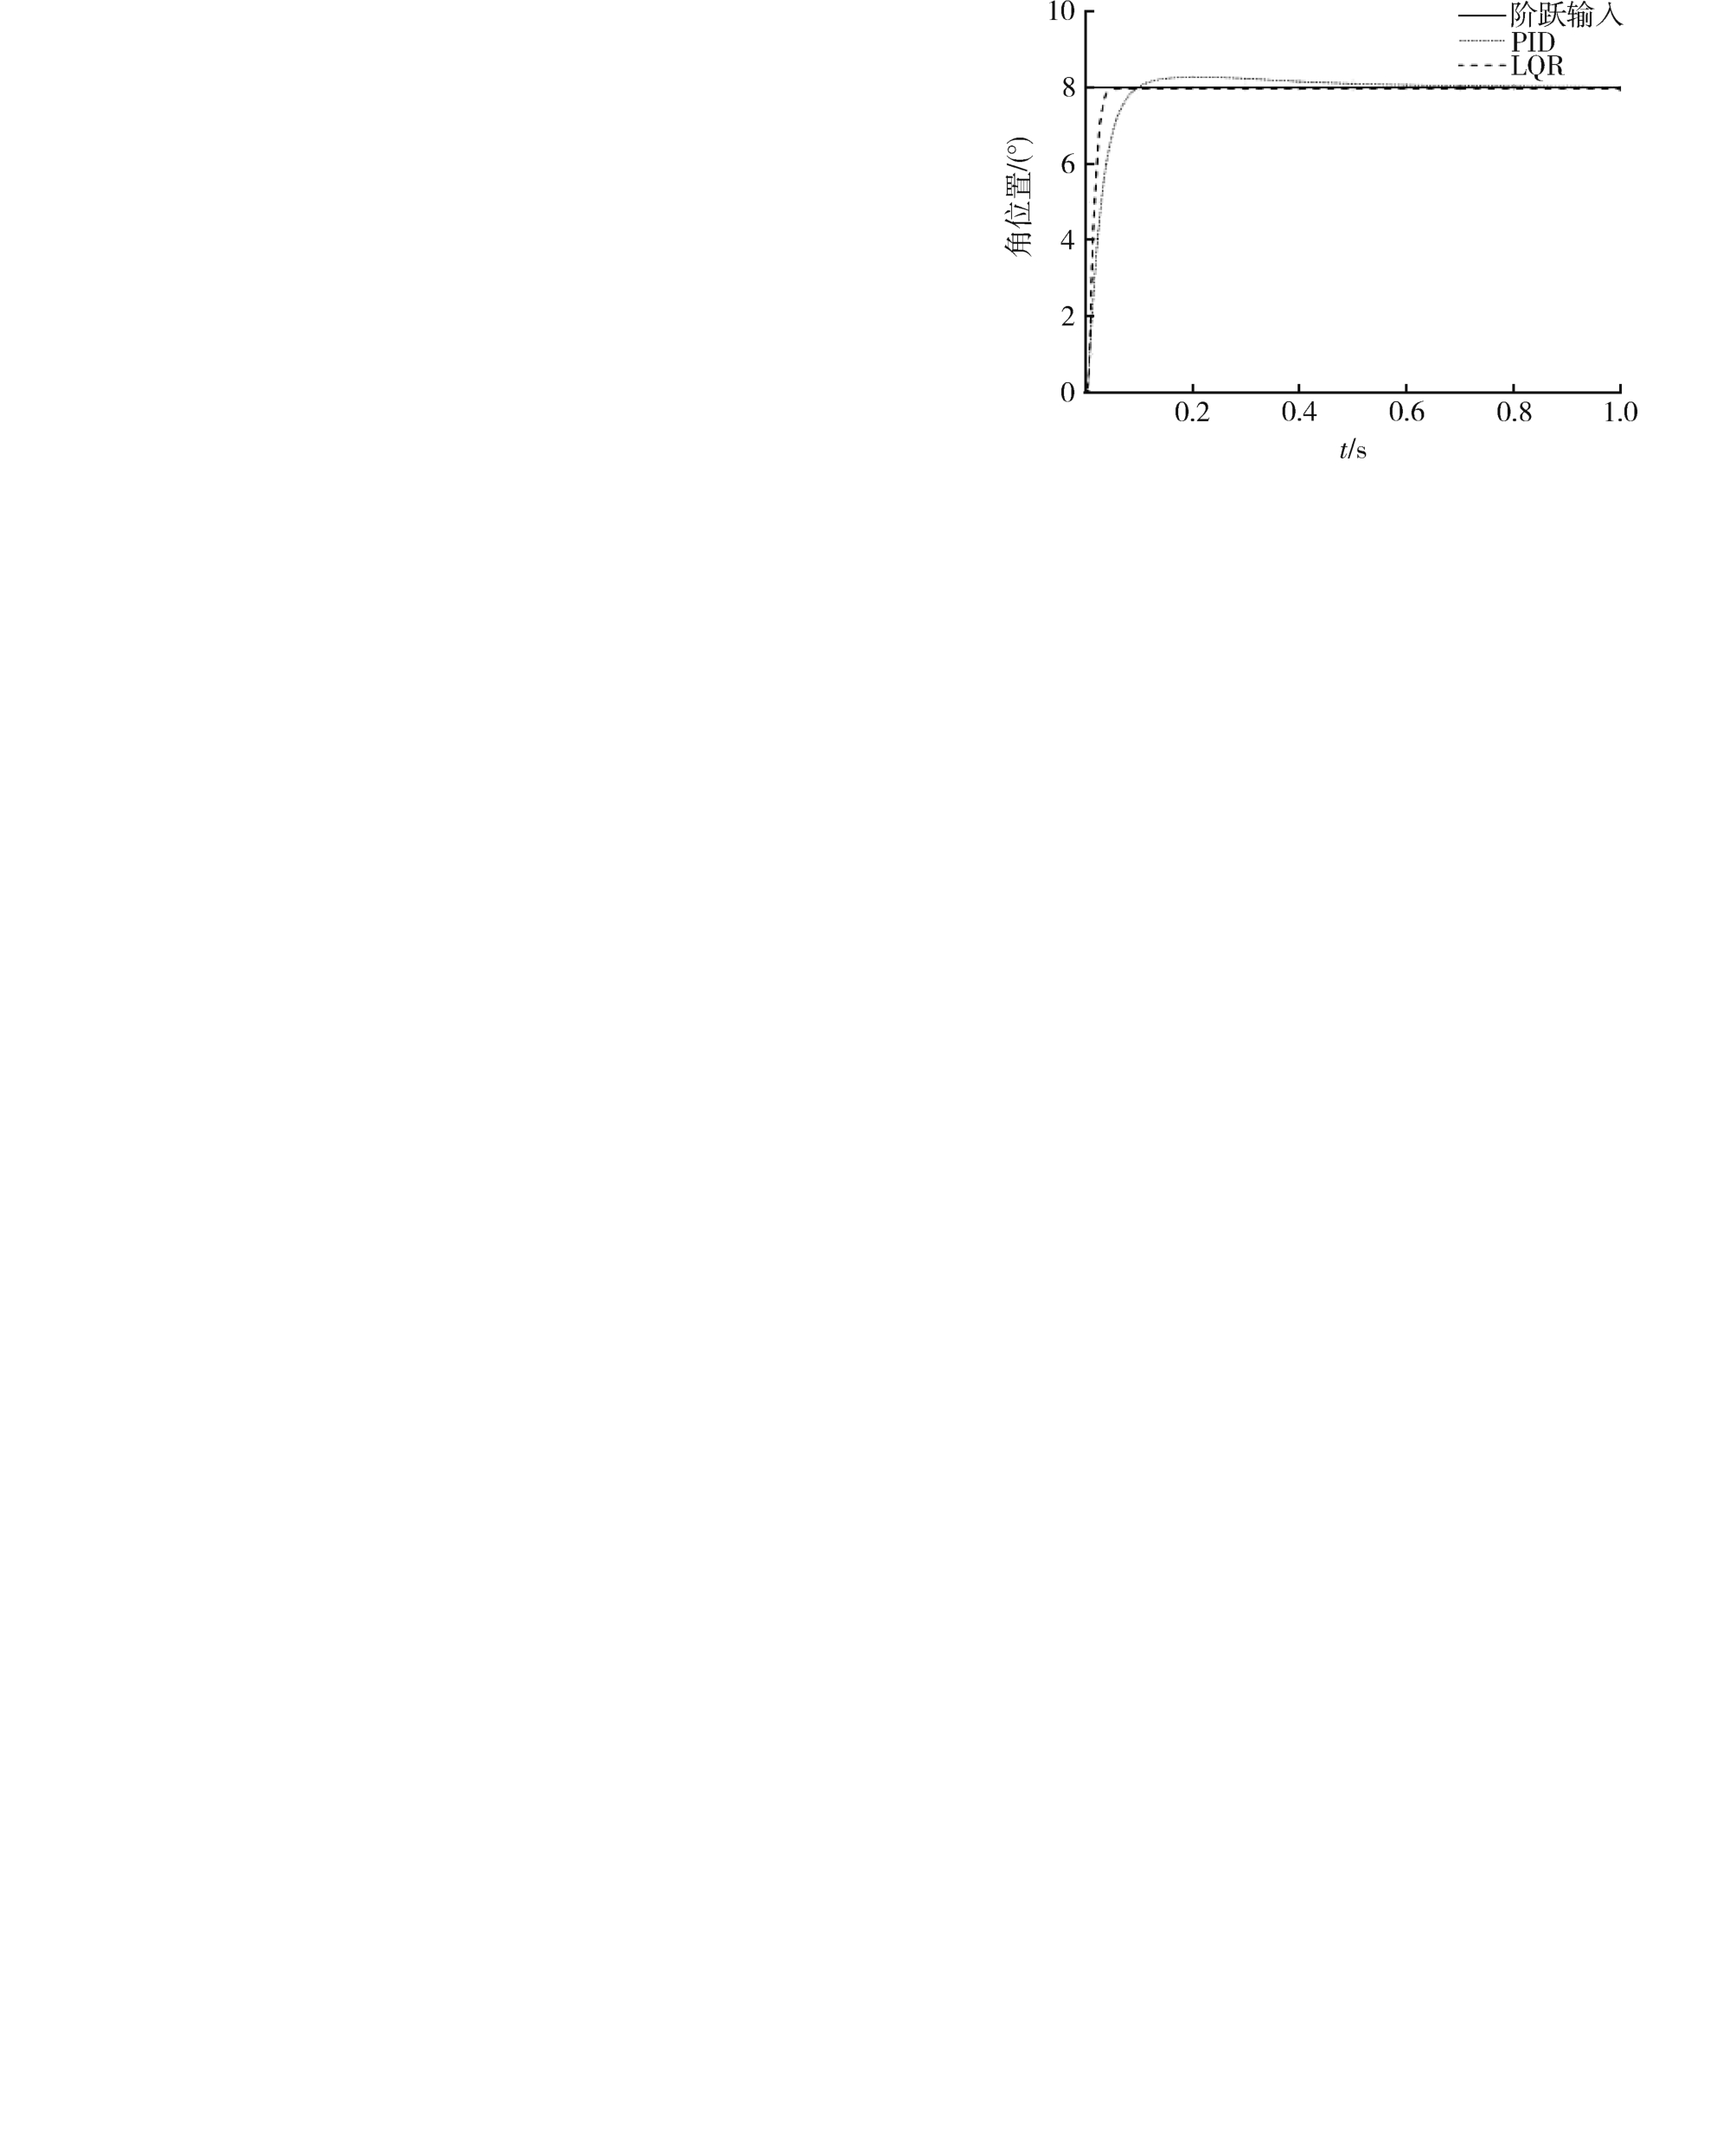
Fig. 10 Simulation results of the presetting stage
Table 2 Simulation result data of presetting stage
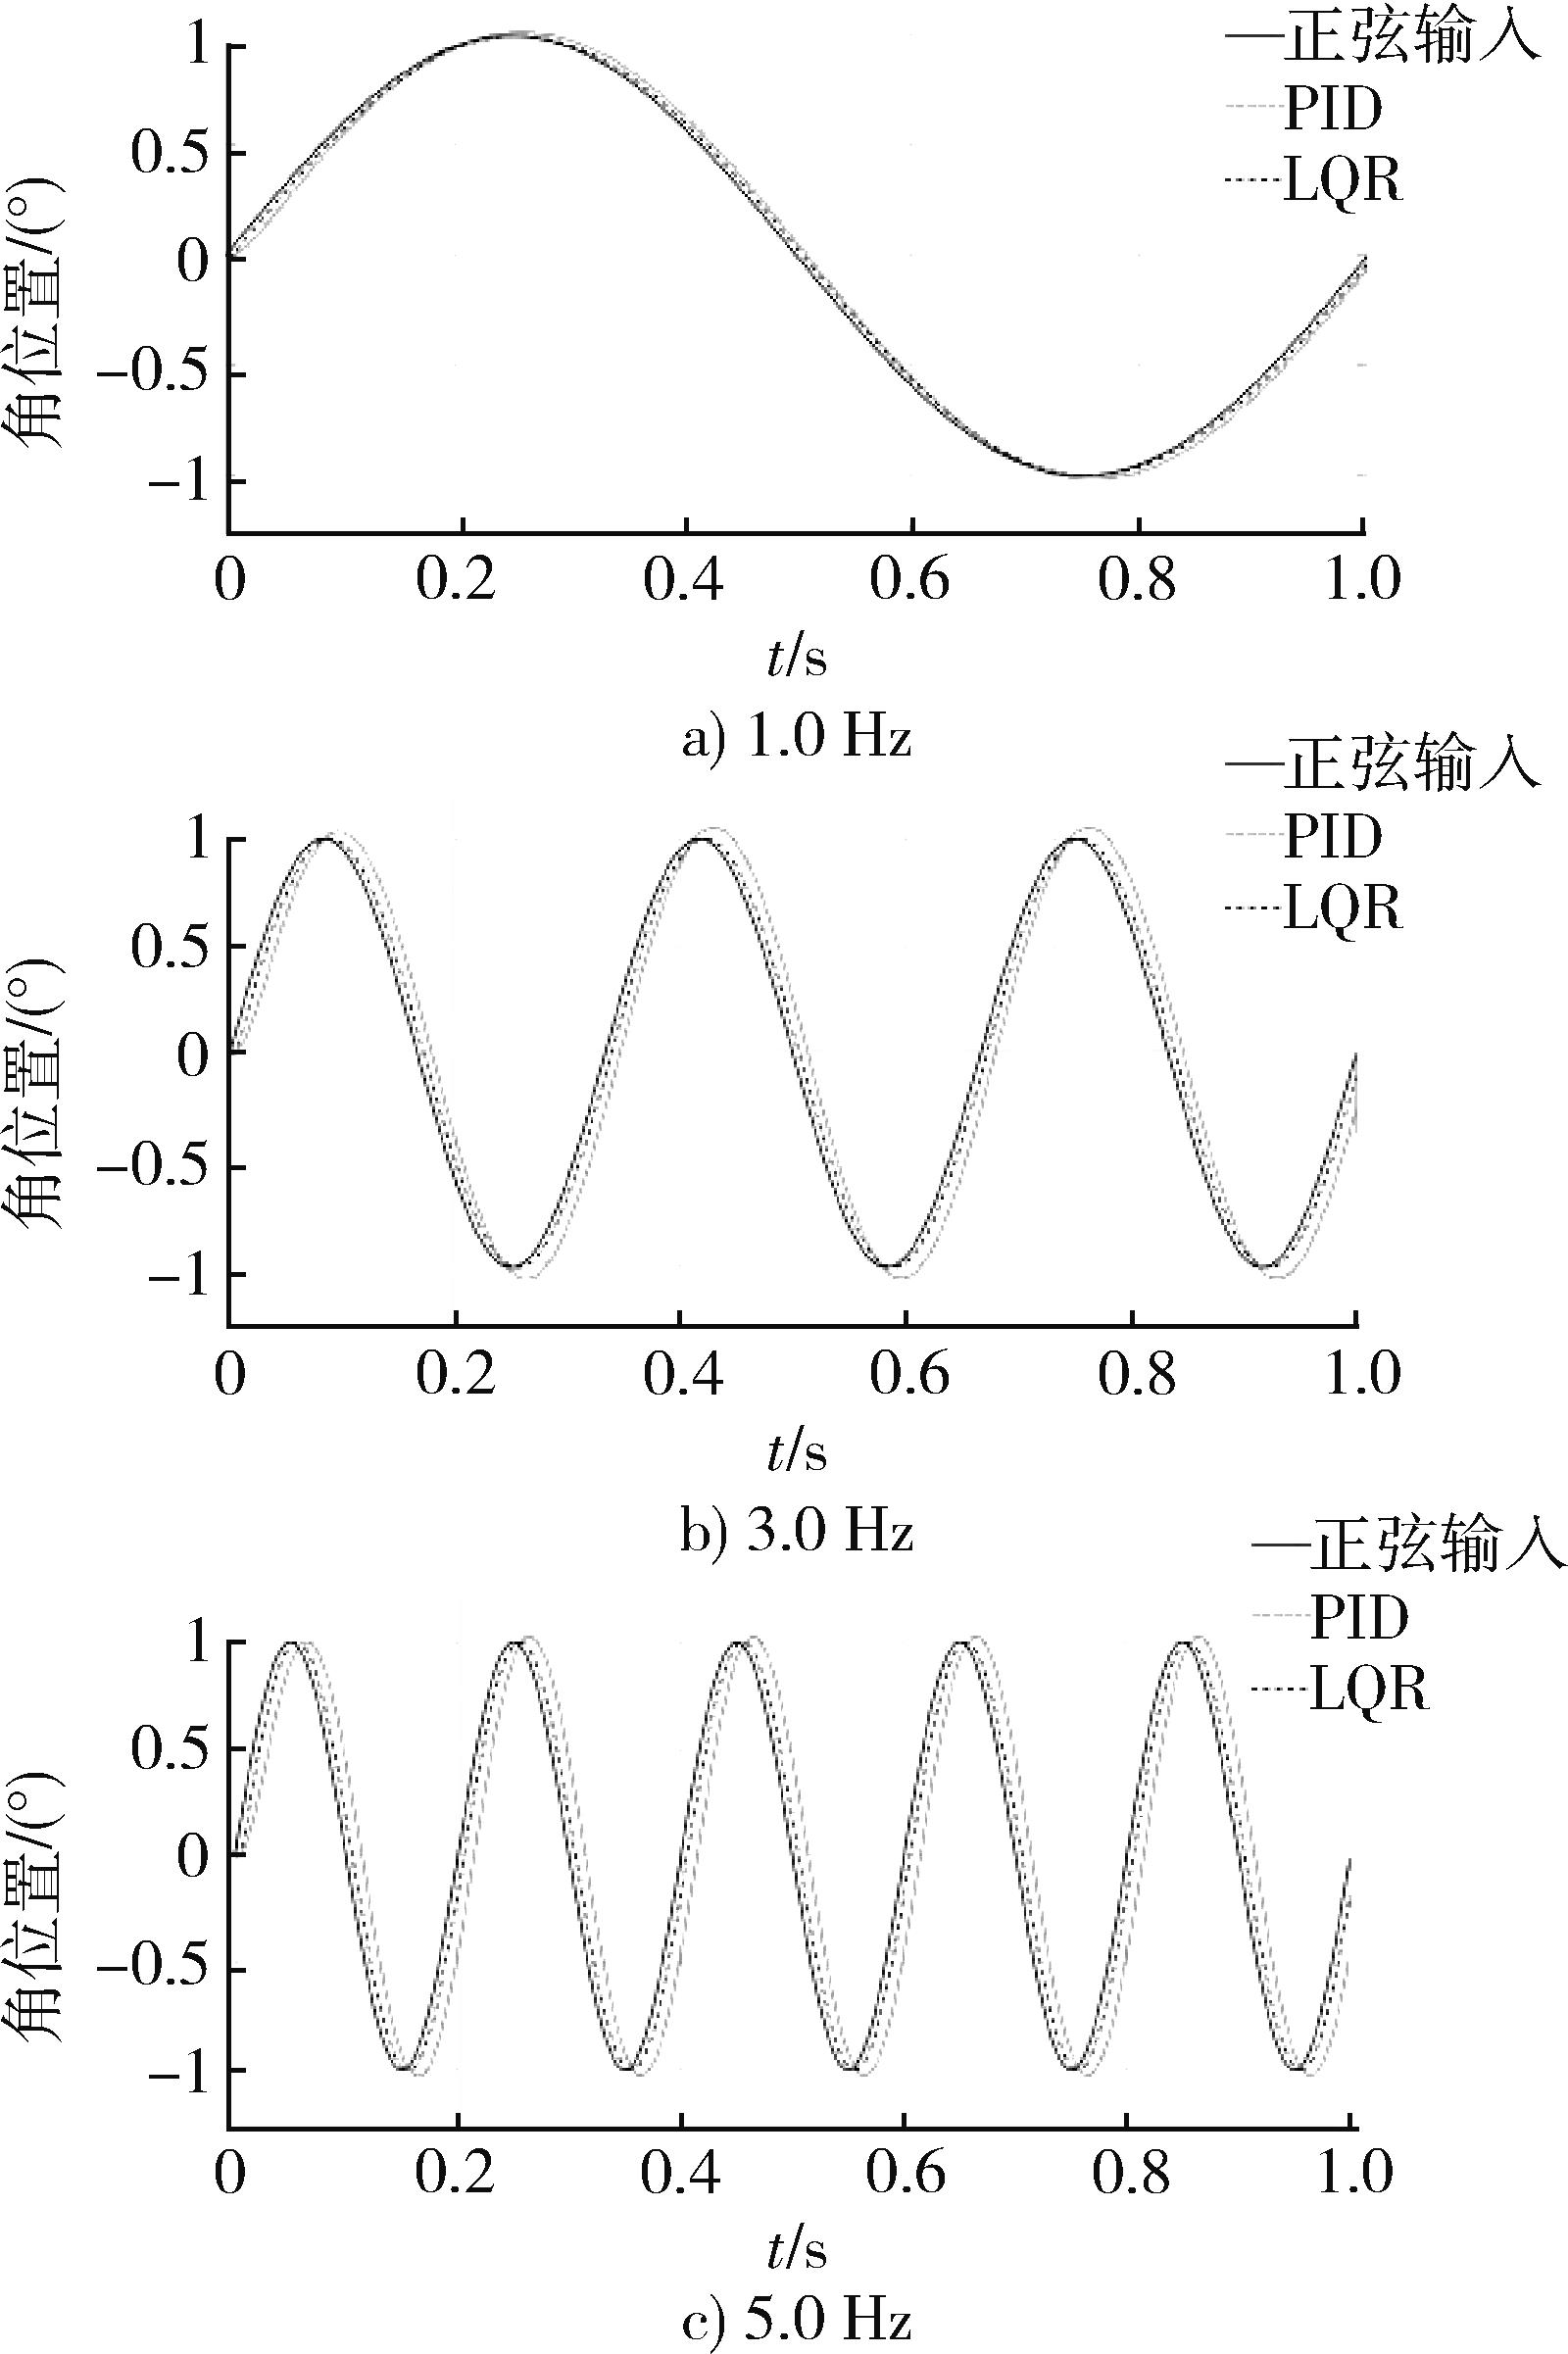
Fig. 11 Simulation results of steady stage
Table 3 Simulation result data of steady stage
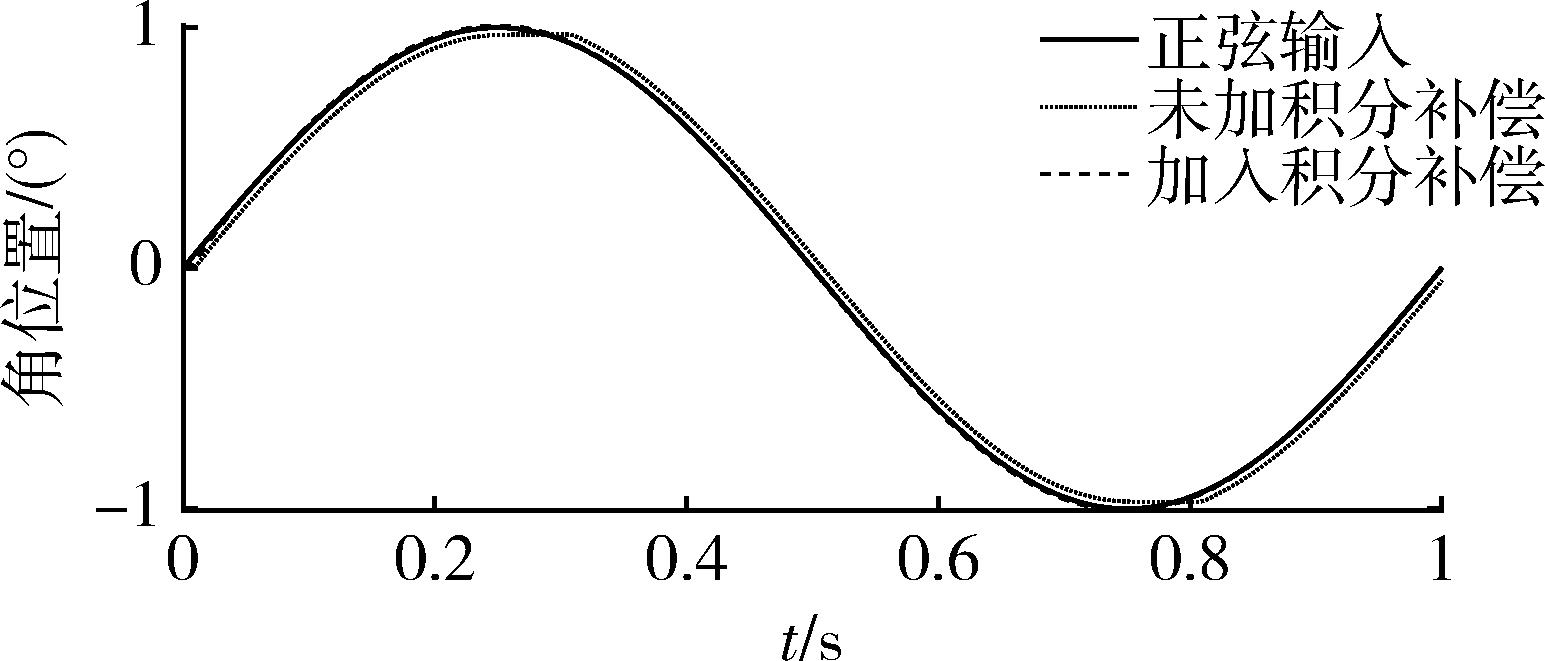
Fig. 12 Simulation of integral control
Table 4 Simulation data for integral control
Fig. 13 Test results for the presetting stage
Table 5 Presetting stage test results data
Fig. 14 Test results for the steady stage
Table 6 Steady stage test results data
Fig. 15 Performance improvement in steady stage
Table 7 Performance improvement data in steady stage
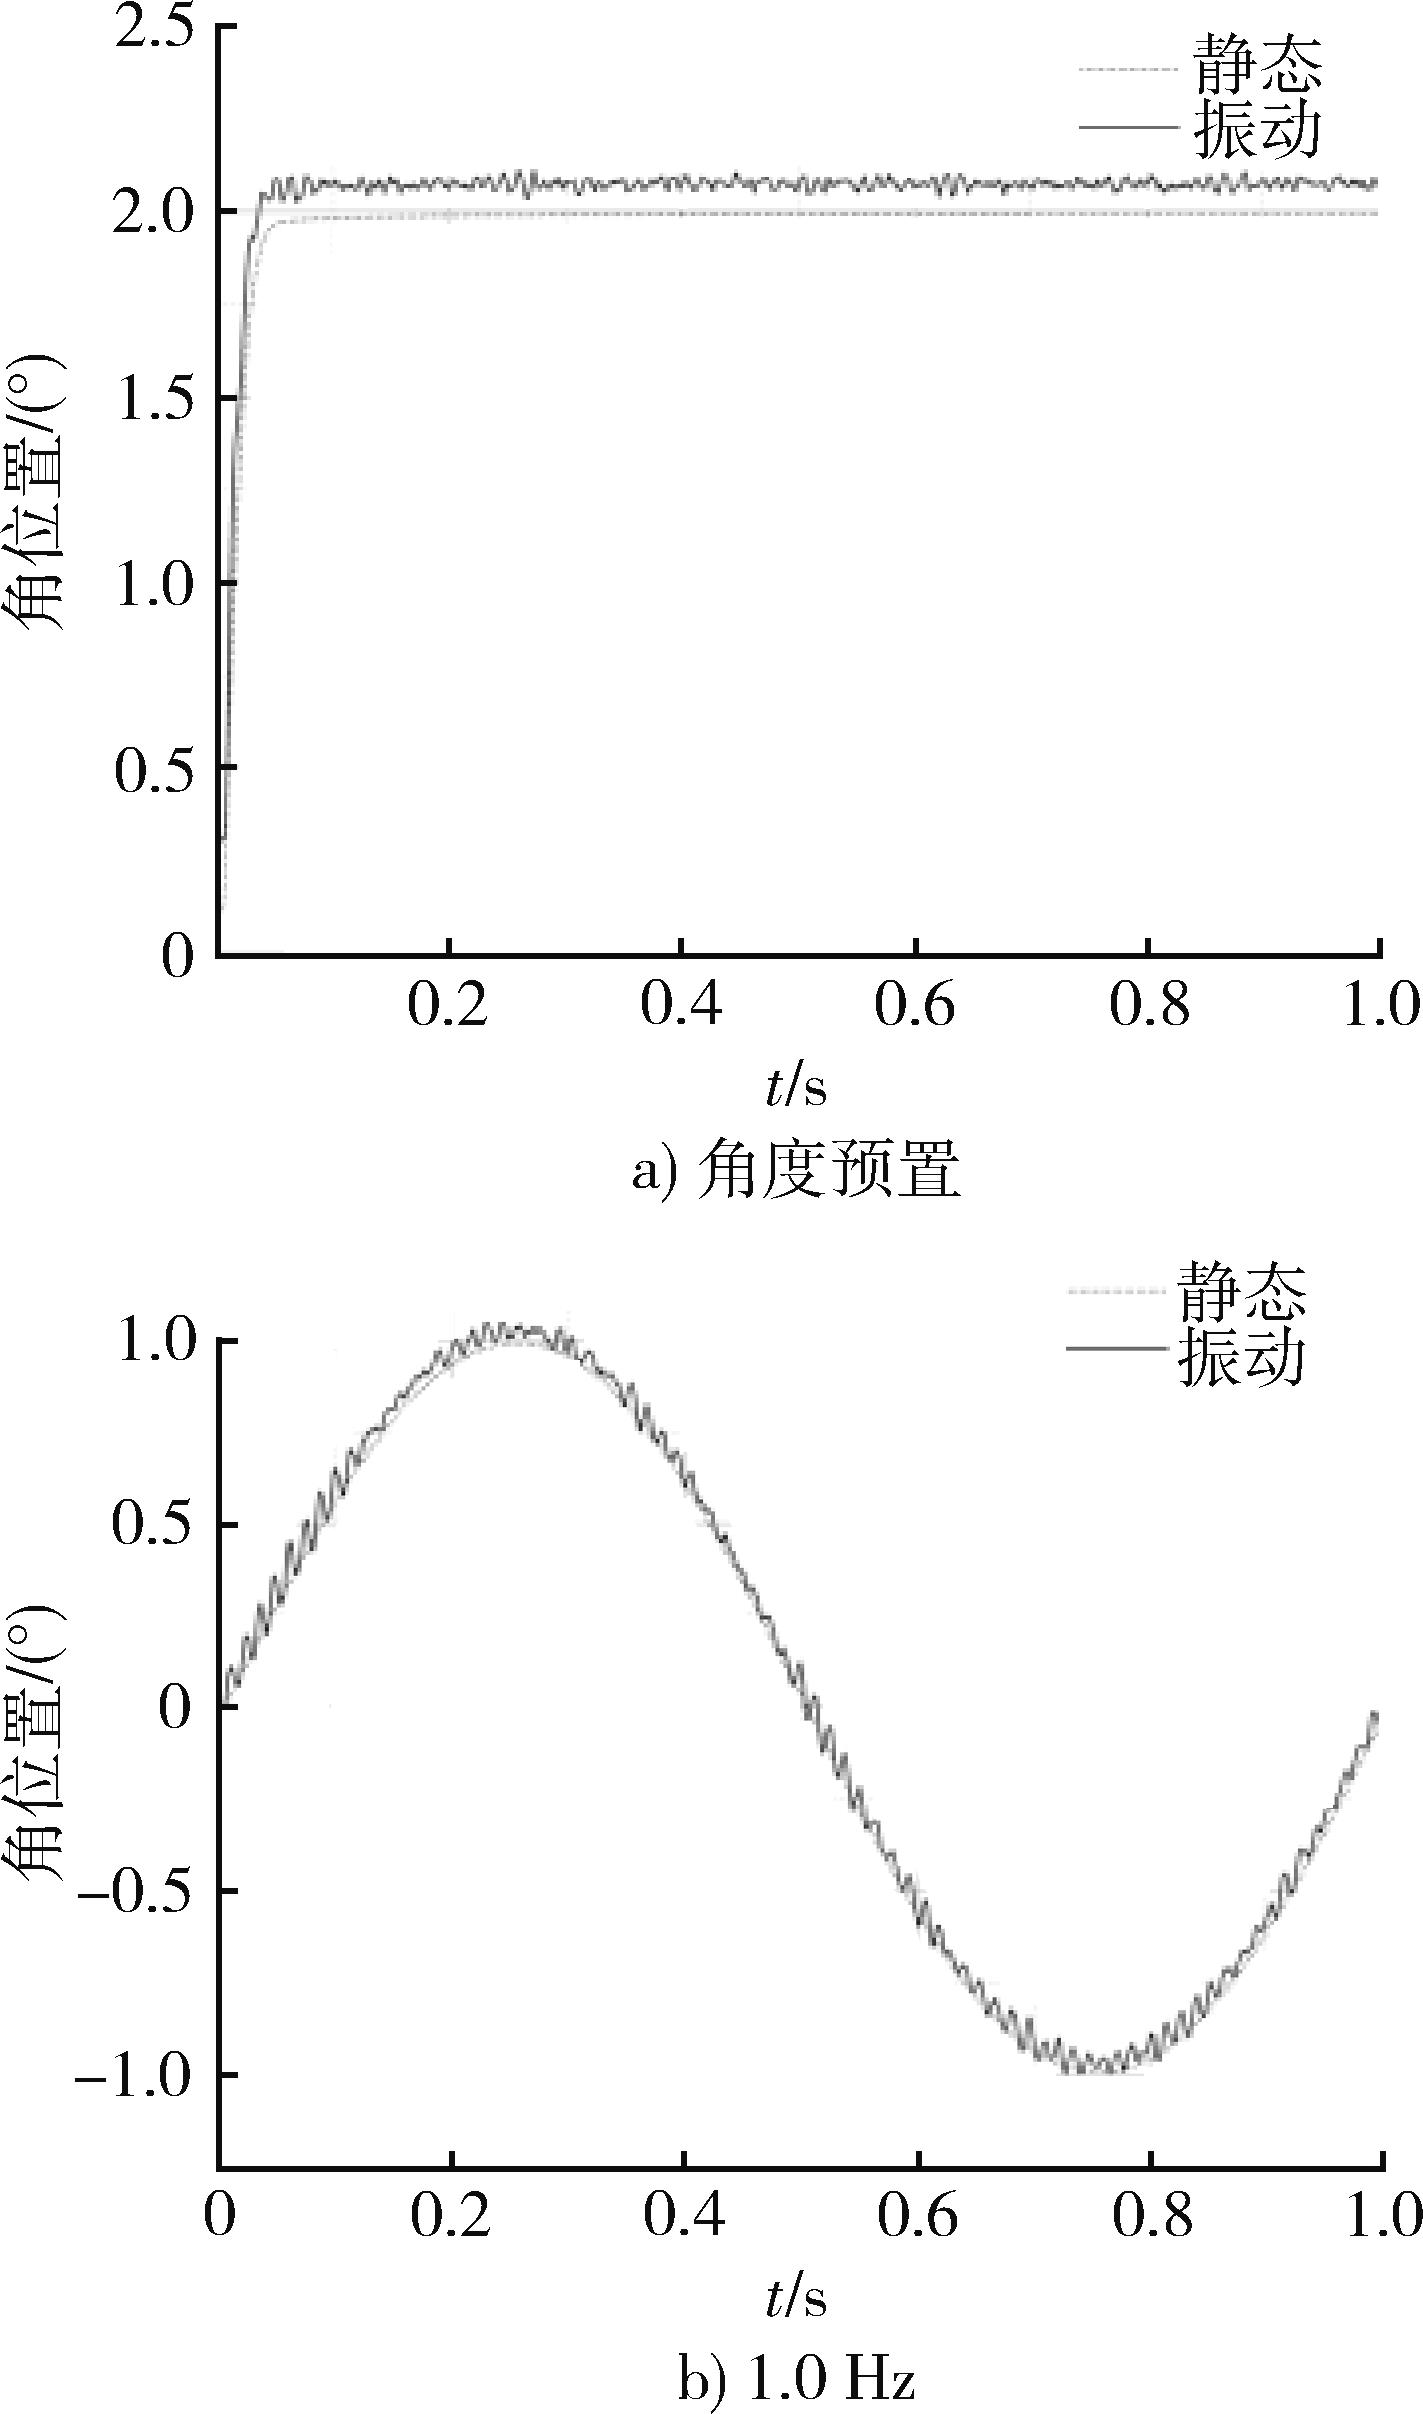
Fig. 16 Vibration test results